How to Choose the Best Passive Walking Robot

Choosing the best passive walking robot starts with understanding what “passive” means. These machines use gravity, body geometry, and joint motion to produce a walking gait, sometimes with limited actuation. That design can reduce control demands, but it does not guarantee low energy use or reliable movement on every surface.

The International Federation of Robotics’ World Robotics 2024 report counted about 4.28 million industrial robots operating in factories worldwide in 2023. This figure describes industrial robots broadly, not passive walkers specifically. It does, however, show why clear performance testing matters as robotics expands. Research by Collins, Wisse, and Ruina in Nature (2005) demonstrated how passive-dynamic principles can inform efficient bipedal design. Their work offers a useful engineering reference, not a universal buying guide.

Compare robots against the job they must perform. Check walking speed, slope limits, step consistency, payload, runtime, and recovery after a stumble. Ask whether testing included carpet, hard floors, ramps, or uneven ground. A robot that walks smoothly on a lab track may struggle on a workshop floor. Look for documented test conditions, service requirements, spare-part availability, and independent evaluations. Small details matter. Joint wear can change a gait; a weak battery can shorten demonstrations. There is no single best model. The right choice depends on terrain, intended use, budget, and acceptable maintenance. Published specifications can still leave gaps, so request practical demonstrations before deciding.
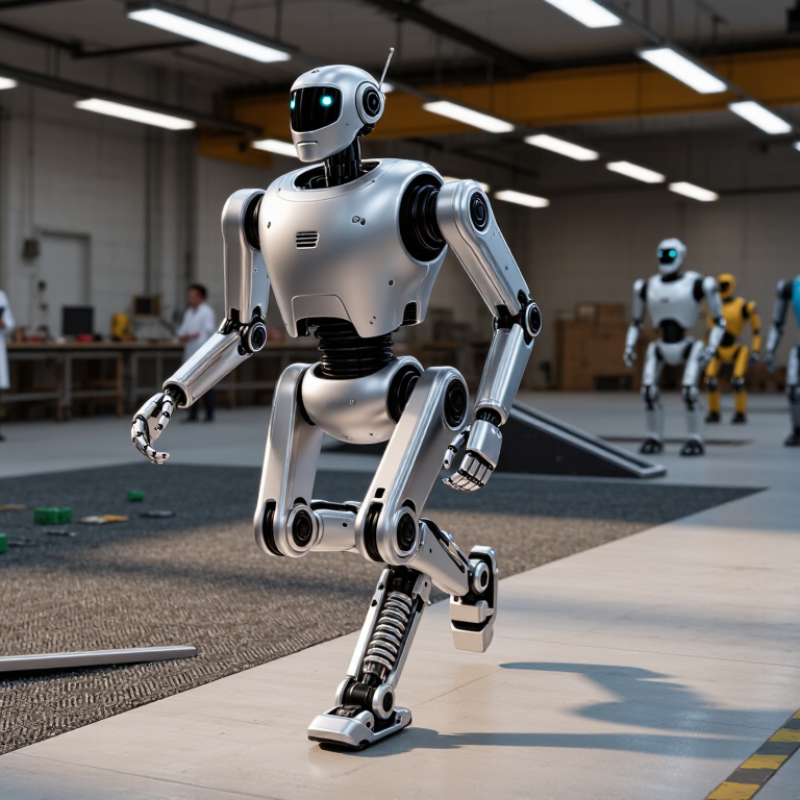
How to Choose the Best Passive Walking Robot

Understanding the Principles of Passive Walking Robots

Passive walking robots move through carefully arranged mechanics rather than powered joints. On a slight ramp, gravity supplies energy as each leg swings forward. Their bodies, curved feet, and linked joints shape the motion, much like a pendulum settling into a repeated rhythm. No controller needs to command every step. The robot’s geometry does much of the work.

That simplicity depends on precise conditions. A gentle slope, suitable mass distribution, and low-friction joints can help produce a steady gait. Too much friction may stop the swing; an overly steep ramp can make steps abrupt. Watch the feet. Their shape affects when the body rolls forward and how the next leg meets the ground. A useful test surface is firm and consistently inclined, with enough space to observe several cycles. A small wobble matters. It may reveal uneven weight, loose joints, or a poor fit between the robot and its surface.

When comparing designs, look for repeatable motion, accessible adjustments, and clear explanations of the intended terrain. Some models work only within a narrow range of slopes. That is not a flaw in every case, but it should be stated plainly. Passive walking is elegant, yet less controllable than powered walking. I still find that trade-off easy to underestimate. Count complete steps, note pauses, and change one variable at a time. This makes the mechanism easier to understand, even when results are imperfect.
How to Choose the Best Passive Walking Robot: Understanding the Principles

About the chart: On a ramp, gravity contributes a downslope acceleration of g × sin(θ), where g is approximately 9.81 m/s² and θ is the ramp angle. A steeper slope provides a stronger gravitational drive for passive walking, but the suitable angle also depends on the robot’s geometry, stability, and walking conditions.

Defining the Robot’s Intended Use and Environment

How to Choose the Best Passive Walking Robot
Defining the Robot’s Intended Use and Environment

Start with the task, not the mechanism. Will the robot demonstrate gait on a lab ramp, carry a light load along a corridor, or support research on uneven ground? These are different design problems. Passive walkers rely on mechanical design and movement conditions, so a smooth, fixed slope may suit a demonstration. Gravel, wet flooring, or changing gradients can disrupt a stable stride. Measure the route: surface texture, slope, step height, turning space, and expected payload. Small details matter.

The International Federation of Robotics’ World Robotics 2024 report records 4,281,585 industrial robots operating worldwide in 2023, a 10% increase from 2022. That figure is not evidence that passive walkers suit every site. It does show how important real operating needs are when choosing robotic equipment. Check whether the proposed robot can start, stop, and recover safely in the intended setting. If people will work nearby, consider visibility, clearance, and predictable movement. One question is easy to overlook: how will the robot behave when the surface is less ideal than the test floor?

Tips: Test on the actual surface, not just a clean model ramp. Record slope, load, and stride stability. Repeat the test; one good run proves little.

Comparing Walking Mechanisms and Structural Designs

How to Choose the Best Passive Walking Robot

Comparing Walking Mechanisms and Structural Designs

A passive walker uses gravity, leg geometry, and momentum instead of continuous motor control. Freely swinging legs and curved feet can create a smooth gait on a gentle slope. A powered hybrid adds small inputs, often at the ankles, to keep walking on level ground. In a 2005 Science study, Collins, Ruina, Tedrake, and Wisse reported that their passive-dynamic-inspired biped used about one-tenth the power of then-current walking robots. That result is useful, not universal: slopes, payloads, and foot design all affect performance.

Compare structures by looking at mass, joint friction, and stability. A light frame may reduce energy demand, but flex under load can spoil step timing. Knee-locking joints can support the body during stance; curved feet can help the legs swing through. Each feature adds trade-offs. I would not assume a simpler frame is always better. It depends on the walking surface.

Tips: Test the robot on the surface it will actually use. Check whether each step repeats, whether the feet clear the floor, and whether small bumps cause a fall. Record power use and step-to-step variation. A short test can miss weaknesses; repeat it with realistic loads and gentle changes in slope.

Assessing Stability, Durability, and Maintenance Needs

How to Choose the Best Passive Walking Robot

Assessing Stability, Durability, and Maintenance Needs

A passive walking robot should feel predictable on the floor, not just impressive in a demonstration. Check how its feet contact the ground, whether joints wobble under load, and how it handles small changes in surface height. Ask for test results covering repeated walking cycles, user weight ranges, and uneven surfaces. The U.S. Bureau of Labor Statistics recorded 885 fatal work injuries involving falls, slips, and trips in 2023. That figure is not a robot-specific measure, but it underscores why stable footing deserves close attention. ISO 13482 also provides safety requirements for personal-care robots, including hazards during normal use and foreseeable misuse.

Durability depends on more than a strong frame. Inspect hinges, fasteners, cables, and foot pads for wear, and ask how often each part needs checking or replacement. Request maintenance logs or endurance-test results, including the test conditions; a large cycle count means little if the load was light. Confirm that routine service can be done with common tools and that replacement parts are available. I would not treat a quiet demo as proof of long-term reliability. It can hide small alignment problems.

Tips: Test the robot on the actual floor and ramp conditions. Watch for foot slip, joint play, and uneven wear after repeated use. Ask for a written inspection schedule, then check whether staff can realistically follow it.

Choosing a Model That Fits Performance and Practical Requirements

Choosing a passive walking robot starts with the job it needs to do. For classroom demonstrations, a compact model with visible joints may teach more than a fast, complex design. For repeated testing, check whether its frame and connectors can handle frequent handling. A robot that walks smoothly on a polished table may stumble on carpet or a sloped surface. Test it where it will actually be used. Small differences in floor texture matter.

Look closely at gait consistency, walking distance, and how easily the model resets after a fall. If it is meant for learners, accessible parts and clear setup instructions can save time. For research, adjustable leg geometry may be more useful than a striking appearance. Consider storage, transport, and repair needs too; these are easy to underestimate. Start small. A low-cost model can reveal whether the walking mechanism suits your goals before you commit to a more elaborate build. Still, performance claims can be hard to compare when test surfaces and methods differ. Record a few repeat trials, even if the results are imperfect. That gives you a more grounded choice than a single impressive walk.

How to Choose the Best Passive Walking Robot — Choosing a Model That Fits Performance and Practical Requirements
Selection Dimension Small Demonstrator Research Platform Practical Requirement to Check
Best suited to Classroom demonstrations, basic gait studies, and low-cost experiments. Detailed studies of walking dynamics, leg geometry, and stability. Choose according to the task: a simple demonstration does not require a full-scale research platform.
Typical scale Tabletop or small floor-standing model, generally under 0.5 m tall. Human-scale or near-human-scale platform, commonly around 0.8–1.5 m tall. Check available storage, transport access, test-area size, and whether the robot can be handled safely.
Walking mechanism Legs swing freely at joints; gravity and body motion drive the gait. Passive leg motion with adjustable geometry, joint friction, or mechanical damping. Confirm which parts are truly passive. A robot that uses motors to drive its legs is not a purely passive walker.
Power and energy No powered leg actuation is needed during a passive walking trial. May need power for sensors, data logging, or adjustment between trials, even if the gait itself is passive. Ask whether batteries or external power are required for sensing or control. Passive walking still needs an energy source, such as a suitable slope or a push to start.
Test surface Smooth, level floors or a purpose-built inclined track. Replaceable test surfaces and a controlled track are useful for repeatable experiments. Start on a smooth, predictable surface. Loose gravel, tall grass, and uneven ground can interrupt the gait and are not guaranteed to be supported.
Slope requirements A gentle incline may be needed to initiate and sustain downhill walking. Adjustable slope helps researchers study how terrain angle affects gait and stability. There is no single suitable slope for every design. Verify the required angle experimentally and provide a safe run-out area or fall protection.
Speed and repeatability Best for observing the basic gait rather than meeting a target speed. Best when speed, step length, and trial-to-trial variation can be measured. Request measured results for the intended surface and slope. Speed depends on leg design, mass distribution, friction, and starting conditions.
Payload and add-ons Usually limited; added mass can substantially change the gait. May allow sensors or adjustable masses, subject to the design’s tested limits. Do not assume the robot can carry a person or useful payload. Check the documented mass limit and test any added equipment incrementally.
Setup and adjustment Prefer simple assembly, accessible joints, and clear setup instructions. Adjustable leg length, mass distribution, or damping can support more experiments. Check how much tuning is required, whether replacement parts are available, and whether adjustments can be repeated consistently.
Safety and supervision Use a clear test area and keep the model away from table edges and bystanders. Use a guarded track, controlled release, and a plan to stop or catch the robot. Assess fall, pinch, and collision risks before testing. Larger or heavier models need more space and stronger safeguards.
Recommended choice Choose for affordability, portability, and easy observation of basic passive gait. Choose for adjustable parameters, measurement access, and repeatable research trials. Prioritize a documented test setup and verified performance over headline speed or appearance.
Data note: Size descriptions are broad planning ranges, not specifications for a particular product. Performance varies with design and test conditions; confirm dimensions, mass, slope requirements, and measured results for the specific robot before purchase or use.